See clearly. Decide what comes next

An observation should inform the next step. The object’s position, the area of interest and what remains uncertain help determine how to approach, when to make contact and what to review.
Discover
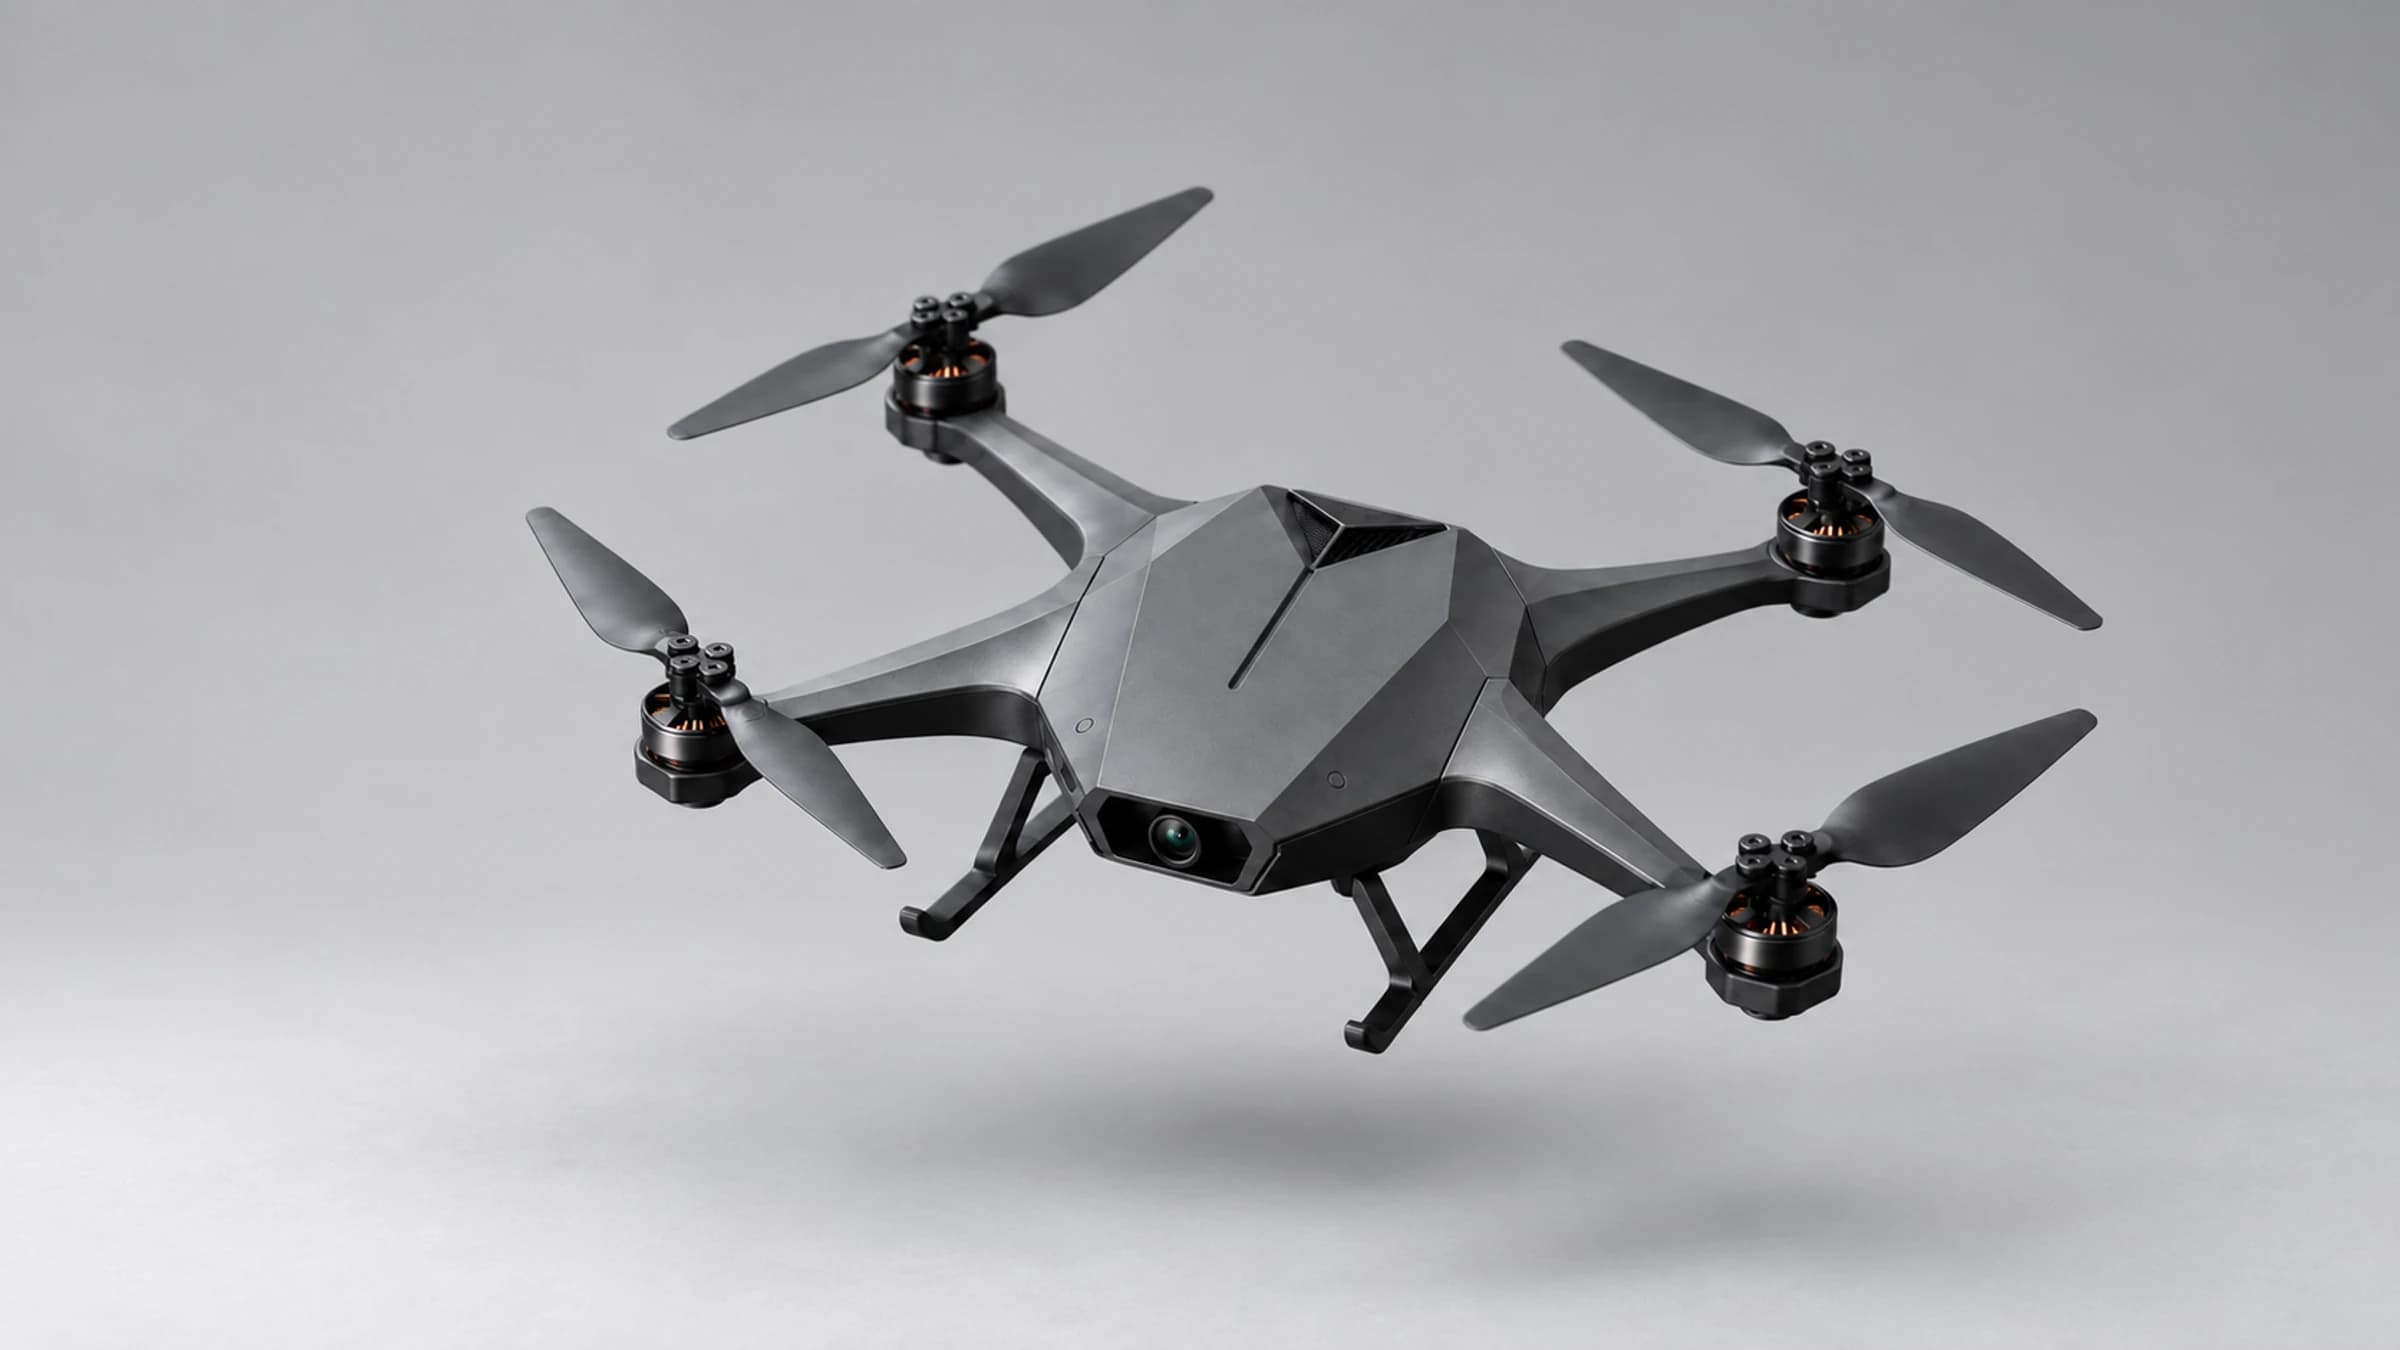
NOEPRA designs flight platforms, interchangeable tools and task software together, exploring how robots can observe an object, approach it and retain a record that can be reviewed.
An observation should inform the next step. The object’s position, the area of interest and what remains uncertain help determine how to approach, when to make contact and what to review.
Discover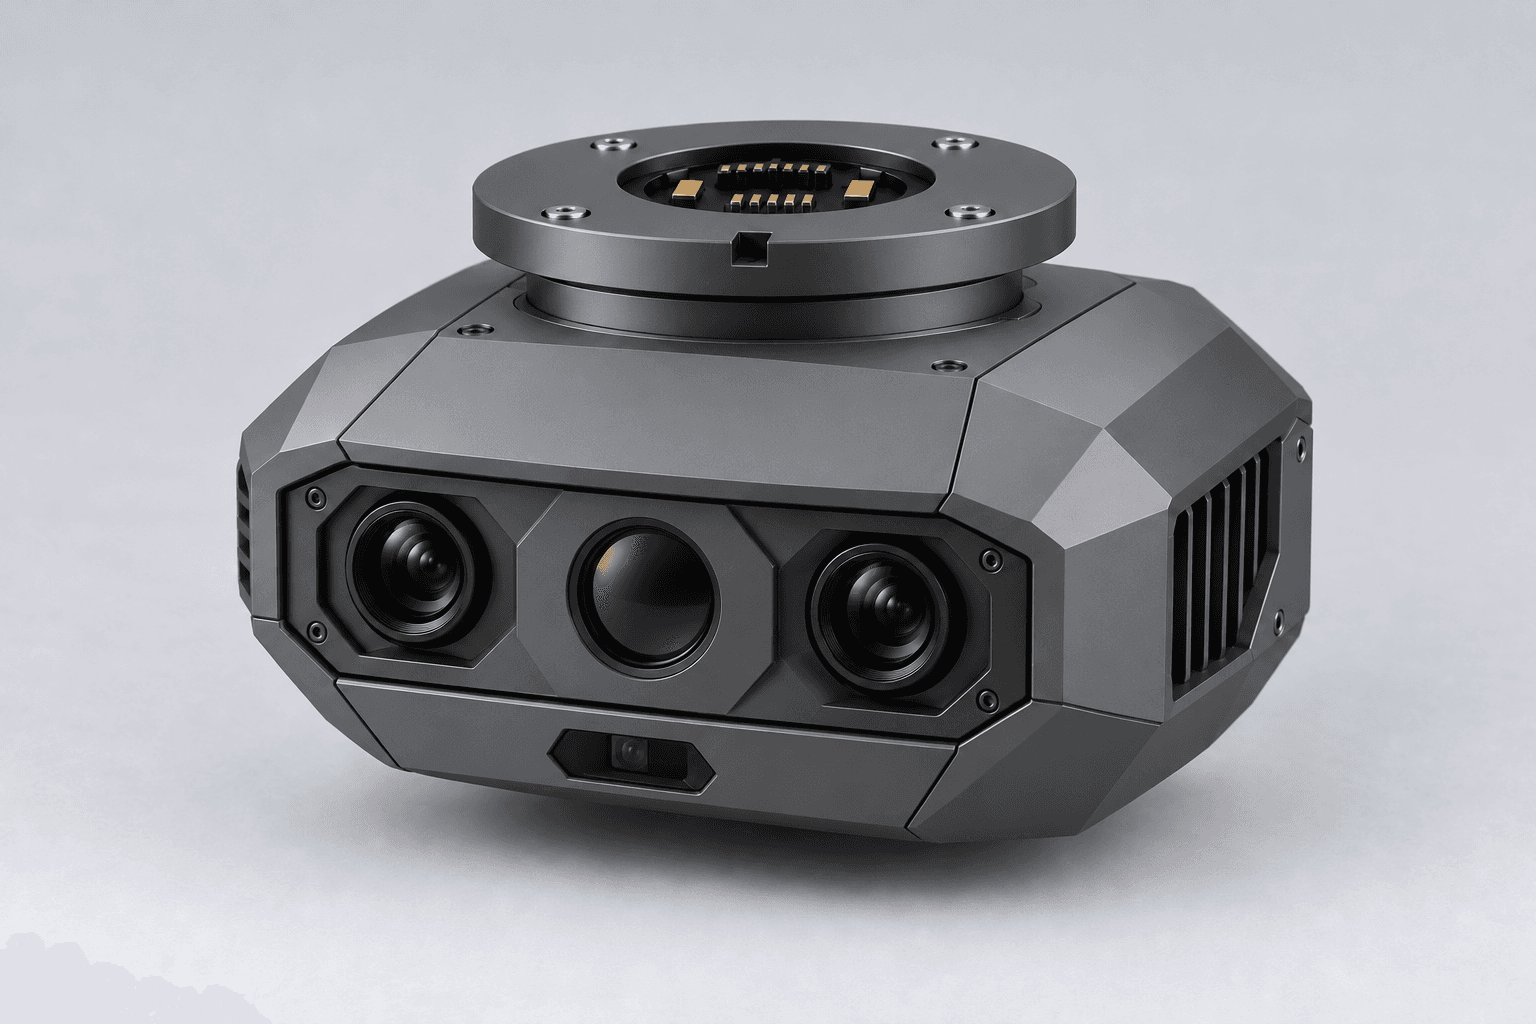
Observation and contact need different working ends. The shared-interface design considers how tools connect to the platform, alongside their mass, power needs and action conditions.
Discover
In NOEPRA OS, an image can carry an area of interest, human comments and a review record. Looking back at a task keeps the source material connected to the judgement.
DiscoverSuper Vision and Adaptive Grasping are our current priority tools.
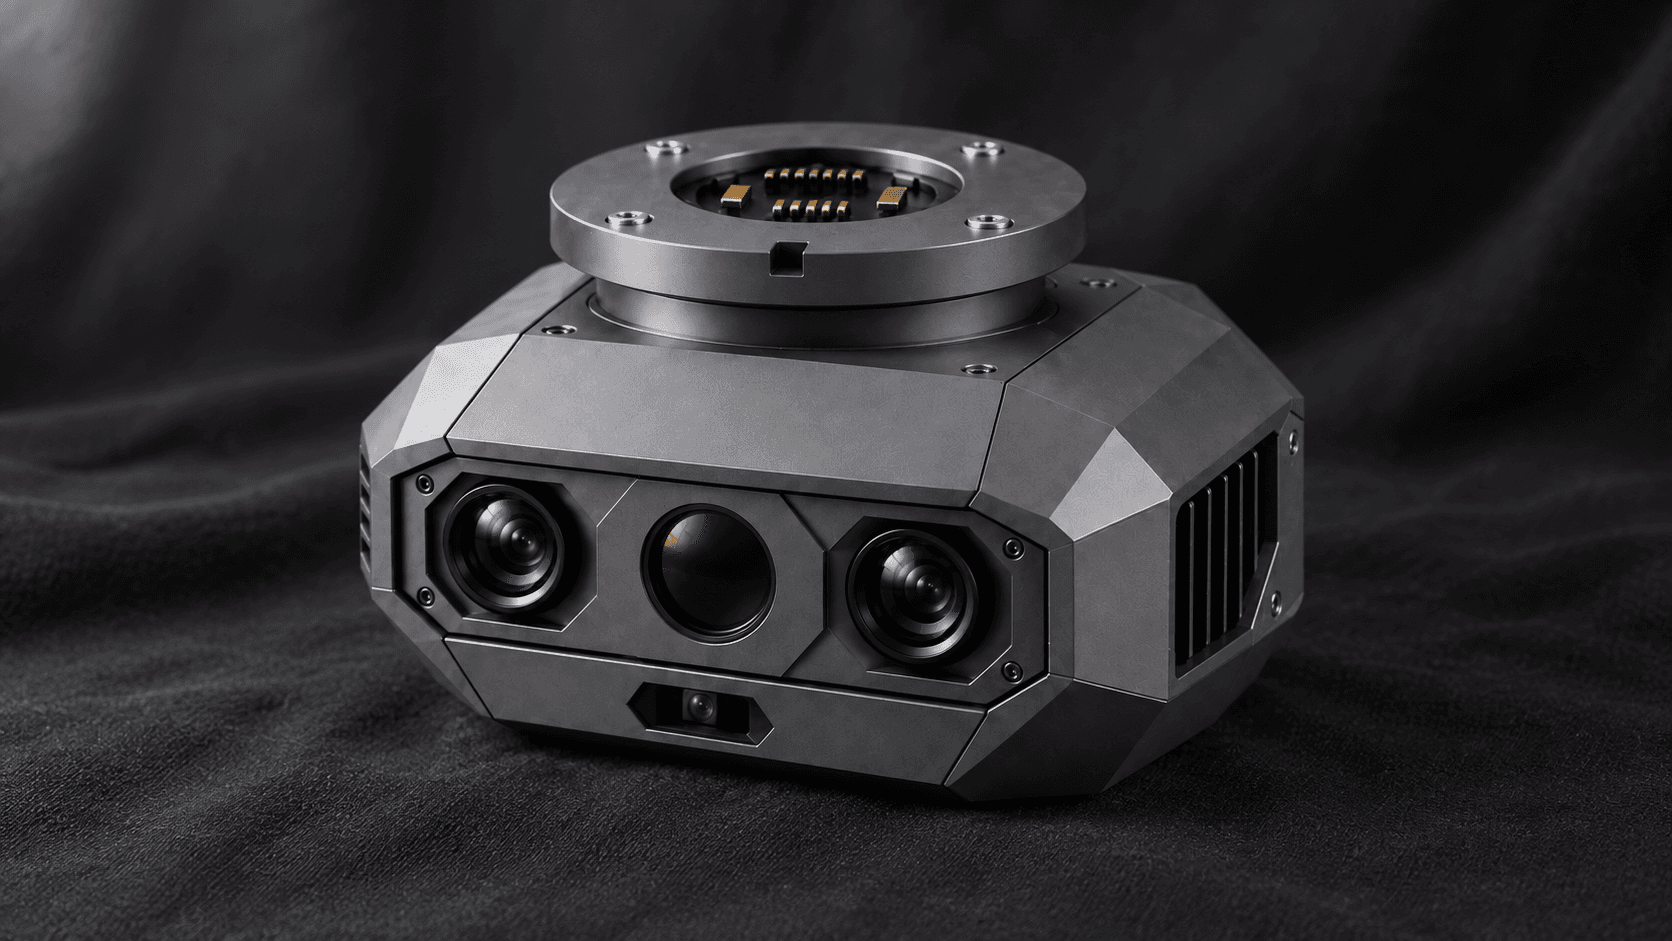
A combined visible-light, distance and thermal-sensing concept for observing objects and assessing an approach.
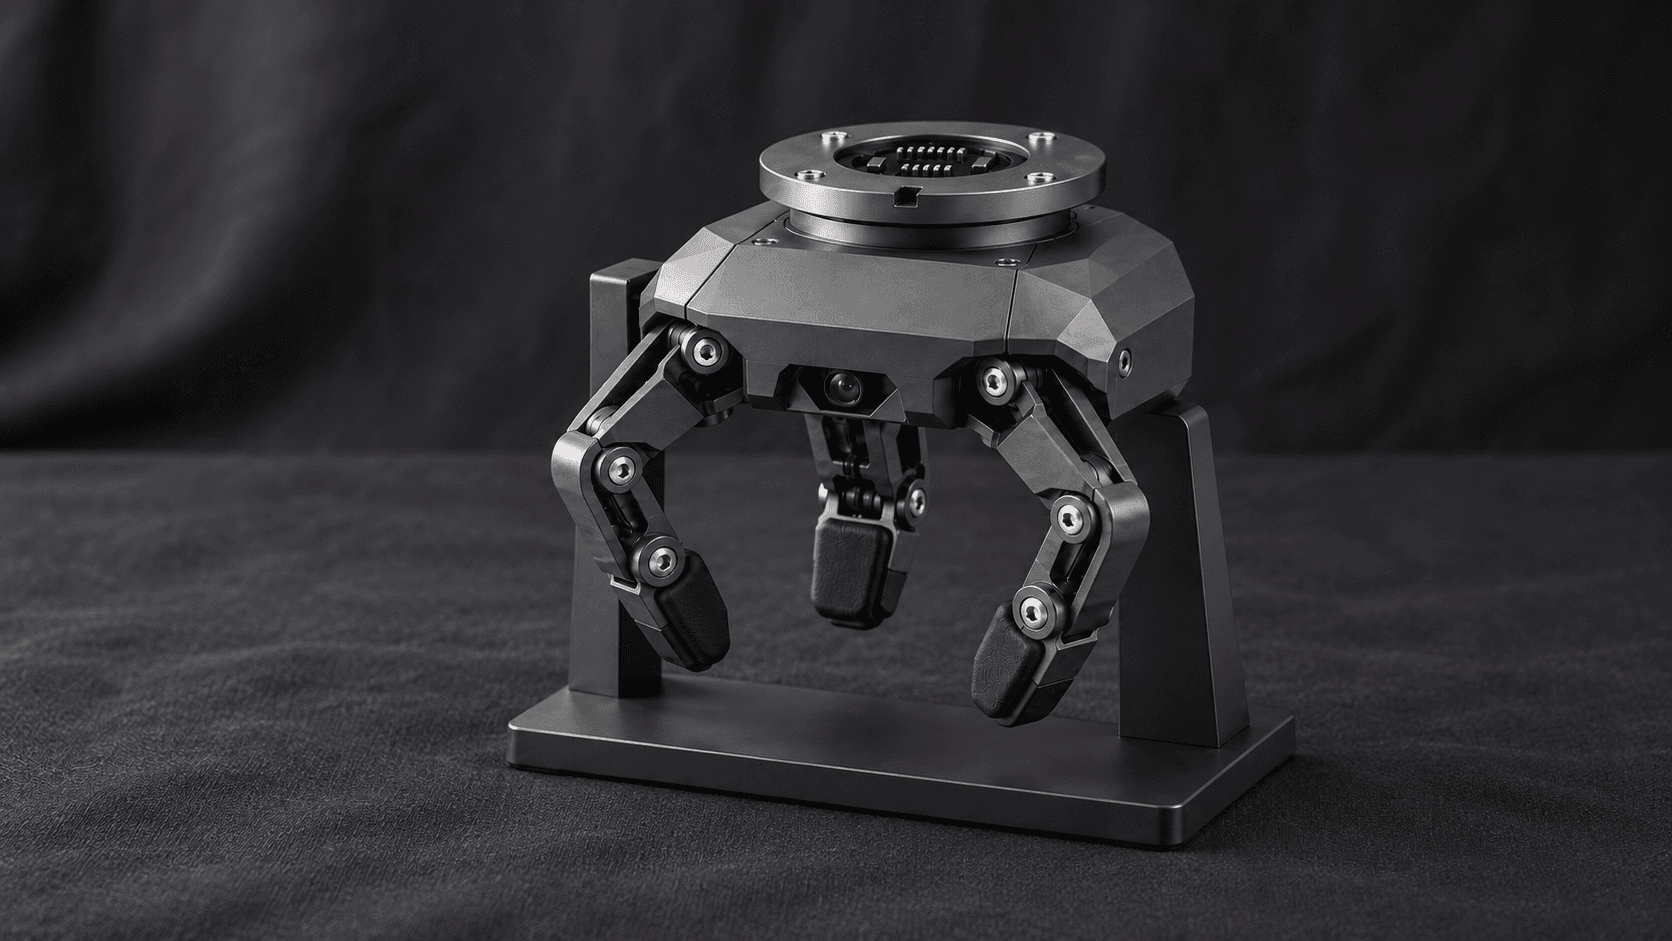
Research into compliant grasping and controlled release of lightweight, irregular objects.
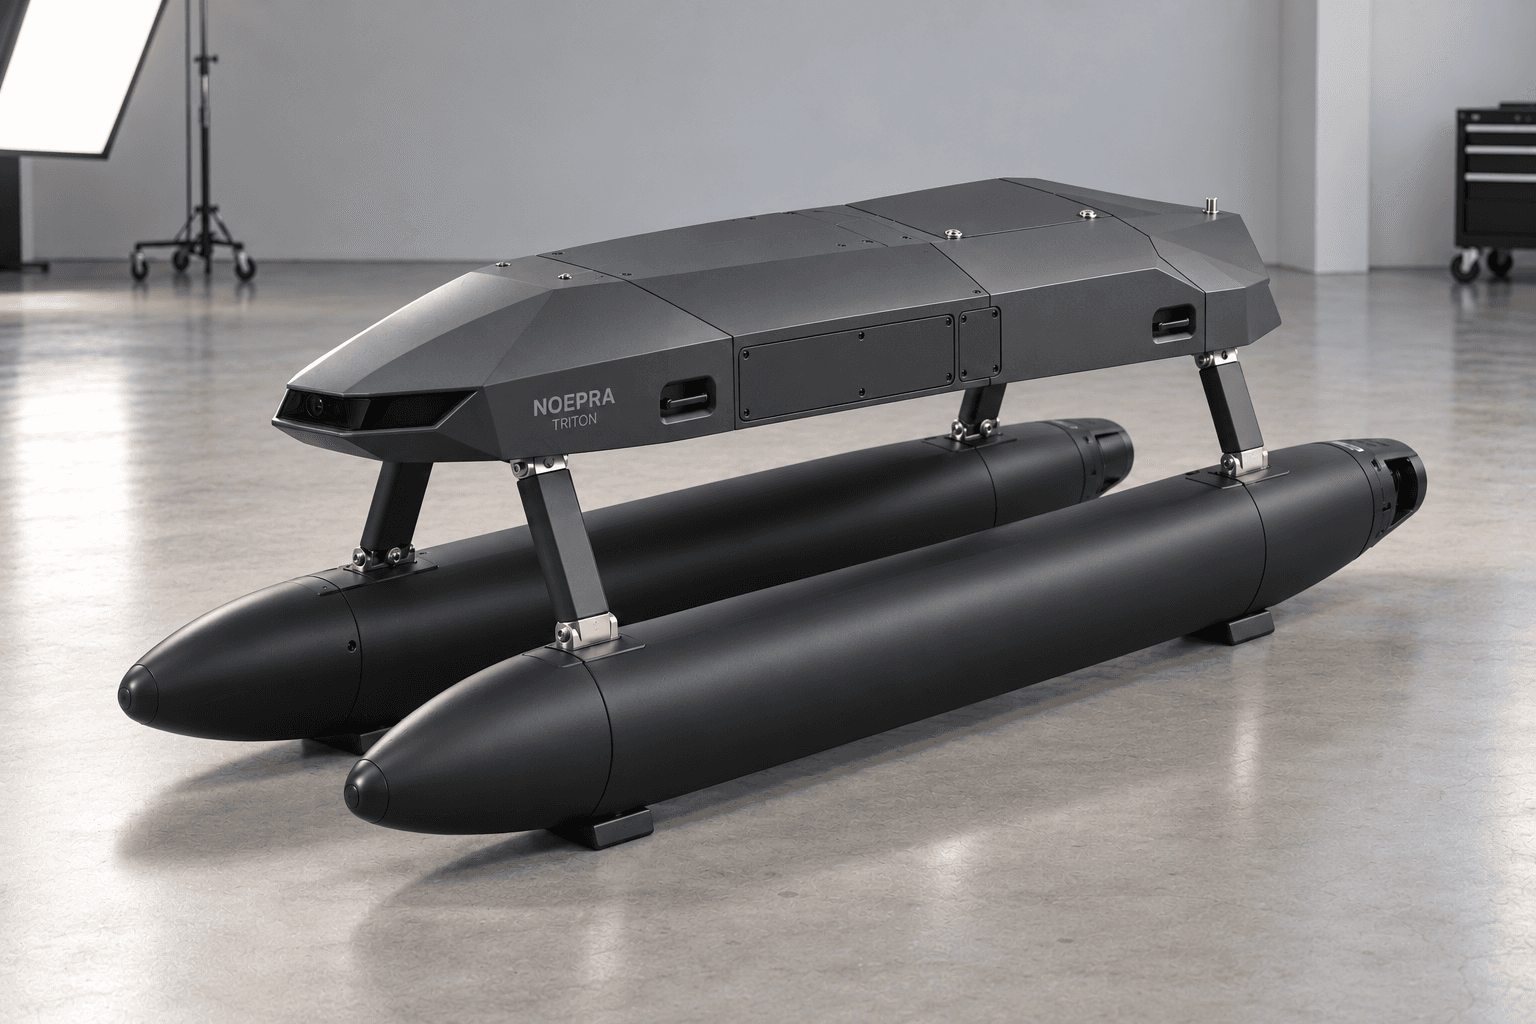
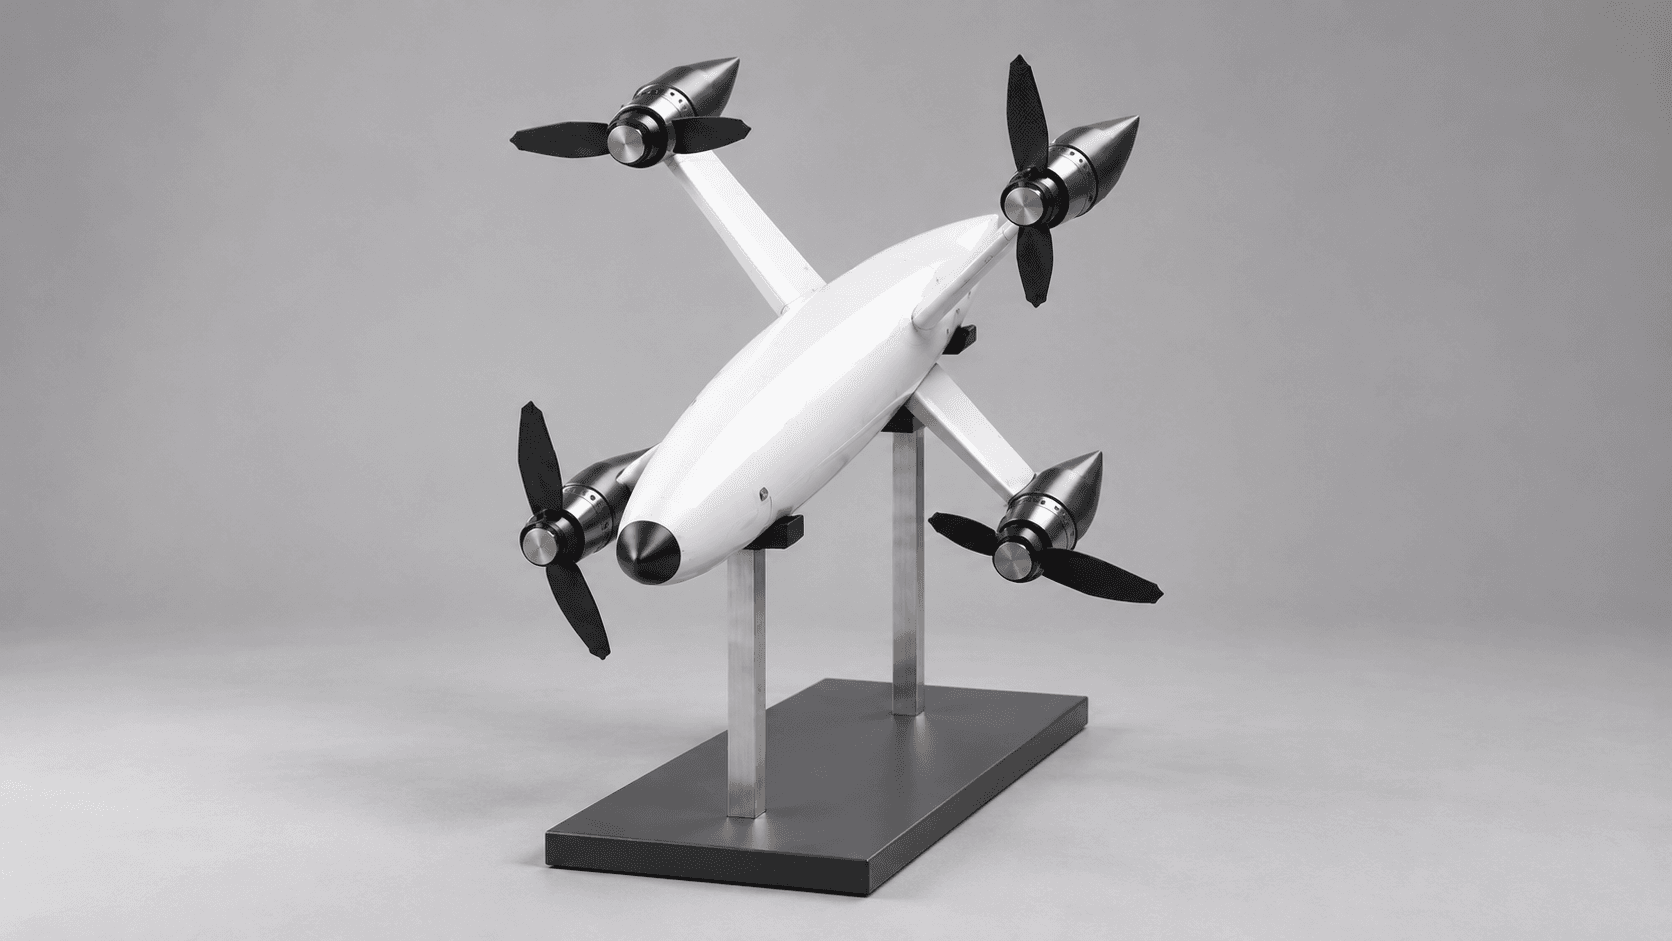
Load and balance in the air, sampling positions on water, preparation and maintenance in the field: each asks something different of a platform. These differences shape our engineering directions.
Some of us start with structures and manufacturing; others with electronics, control and software. Each tool change and prototype revision brings these conditions into the same engineering discussion.
Design versions, prototype development and process records give the next revision a clear basis.