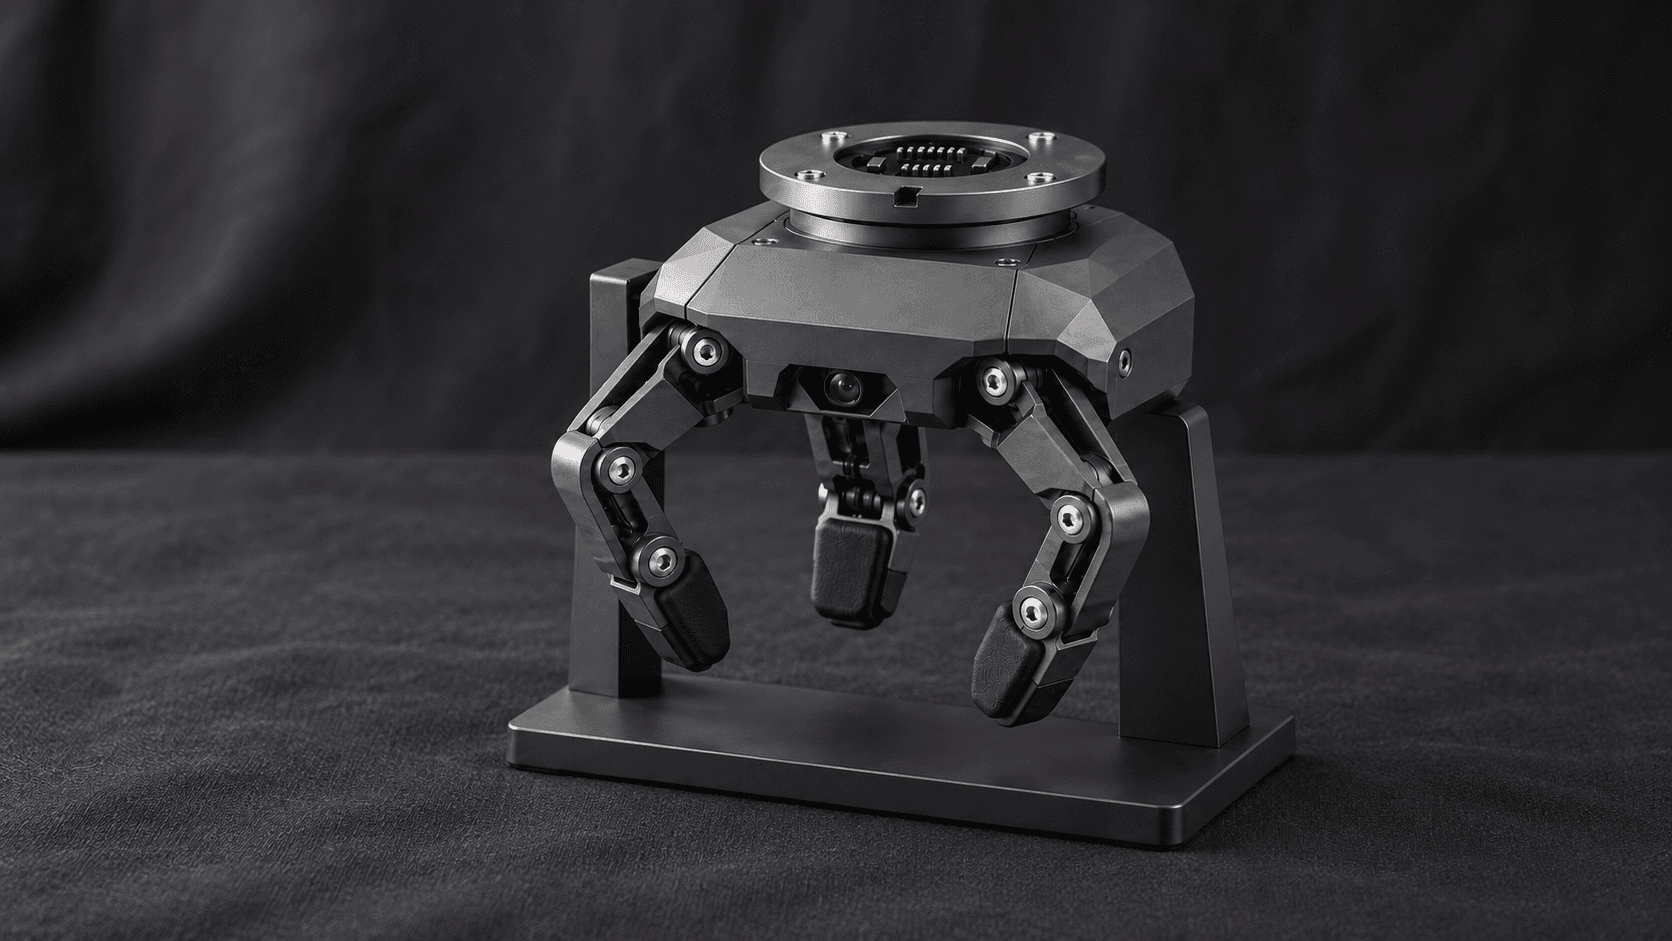
An interchangeable tool for exploring aerial interaction with irregular objects.
Contact. Adapt. Interact
The tool, the object and the conditions around them. Interaction is developed as a replaceable module with a clearly defined role.
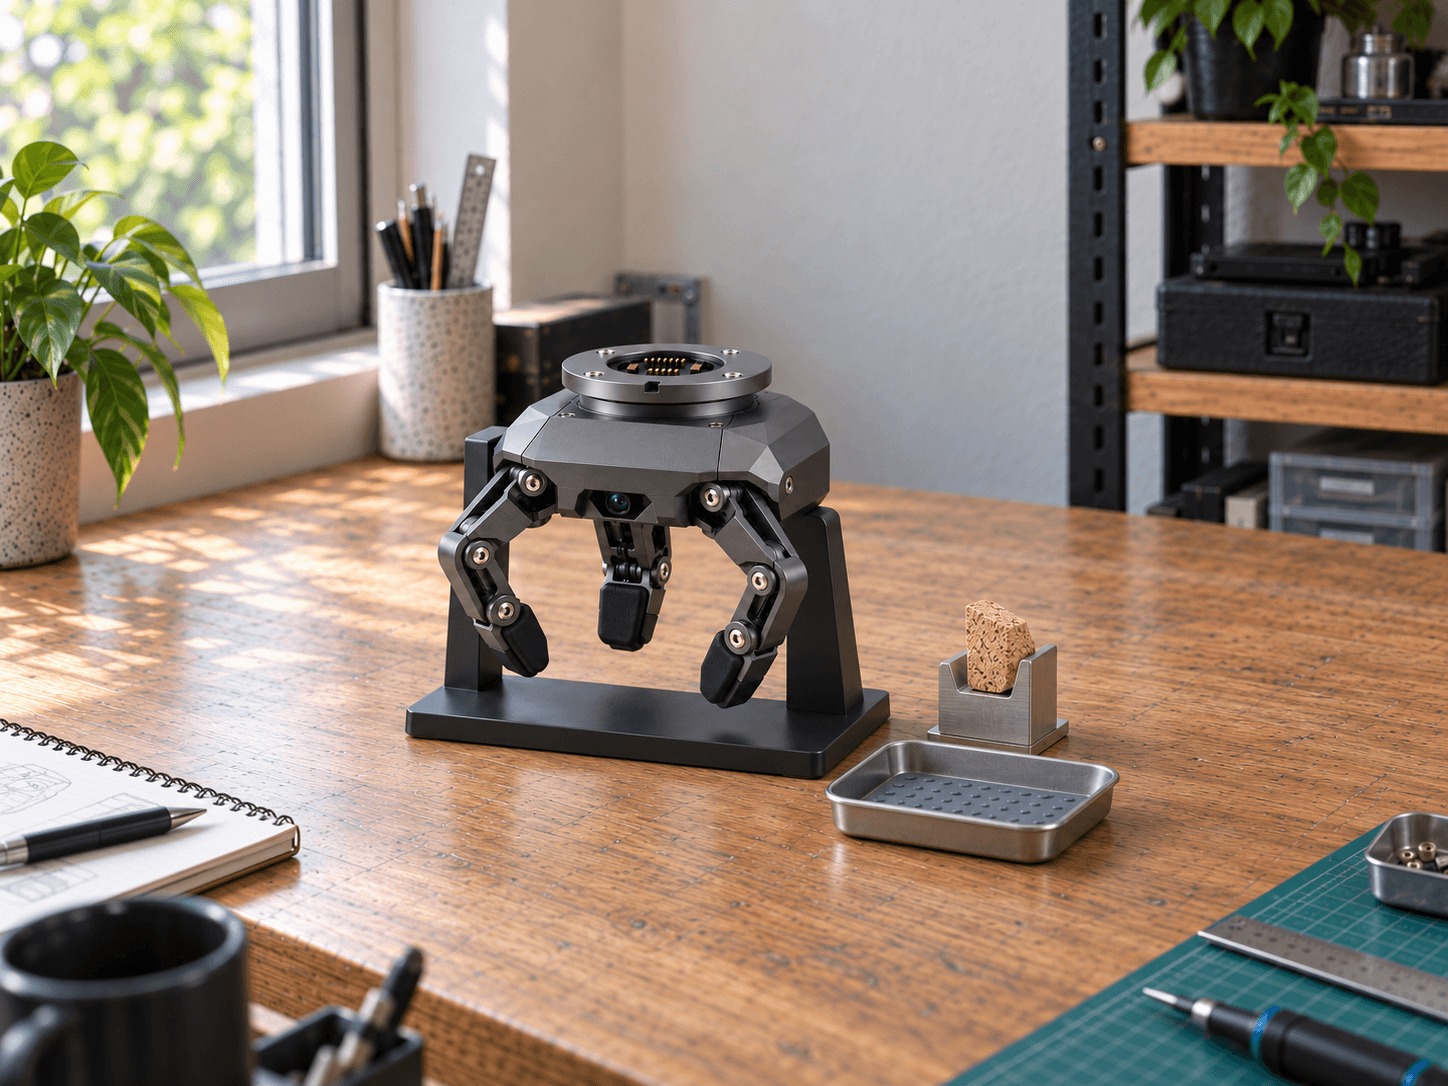
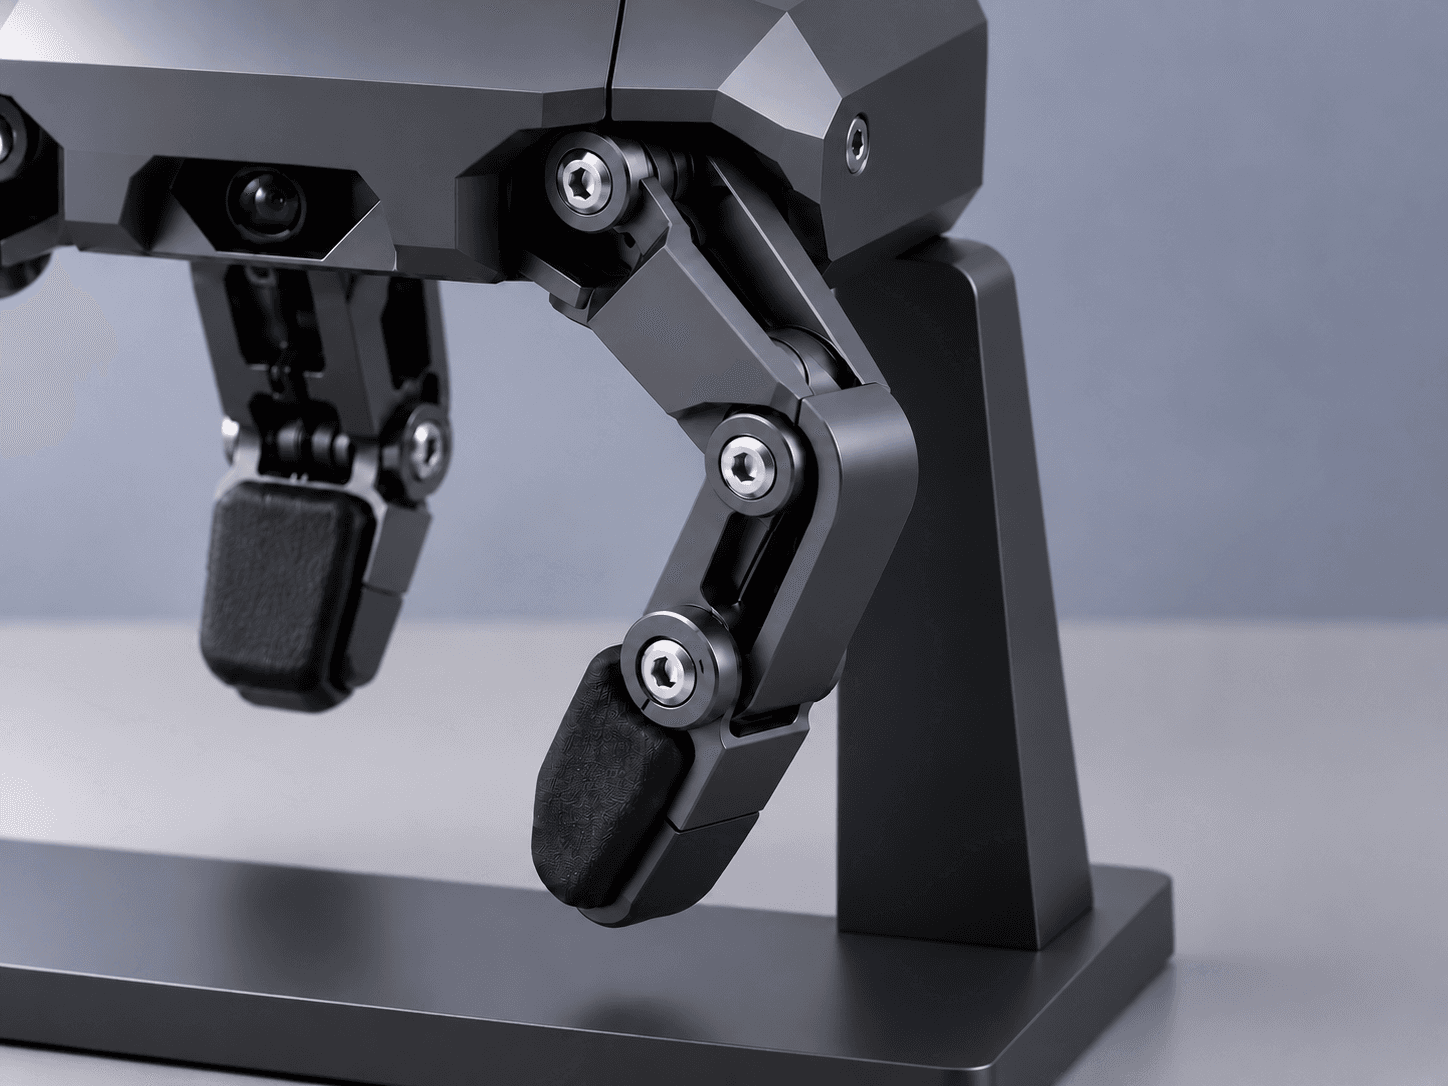
Adapt to the object
Compliant contact and finger concepts are being explored for objects with irregular geometry.
Operating considerations
Controlled contact, changing loads and result verification are key engineering questions in development.
Adaptive Grasping
Adaptive Grasping
Judge the contact by what happens to the object
A gripper should be evaluated across approach, contact, holding and release. The same object can behave differently when its orientation, friction or support changes. Adaptive Grasping research therefore needs observations of slip and contact marks, as well as whether the object was lifted.
For a collaborative trial, provide a representative object, an acceptable contact region and a clear release position. These help define a bounded test and its failure criteria. Bench results can establish contact behaviour; carrying that object in flight remains a separate question.